The S1 Suite

Autonomy, with or without GPS.

Five tools that work on their own and together: navigation, autopilot,vessel control, simulation and vessel models. Maritime first, built to be customized for every platform. Everything we ship today is System 1.

01 · Navigation

Sextant

Position and heading with or without GPS — and it knows when GPS is lying.

  • GPS is just another sensor. Every sensor on board is fused into one trusted position. Sextant works the same with or without GPS, and only leans on it while it is healthy.
  • Jamming & spoofing detection. It notices when satellite positioning is jammed or lying, alerts the operator, and keeps navigating.
  • Calibrates itself in service. It keeps its own calibration up to date while the robot operates, so your crew never has to.
  • Plug-in sensors. Each sensor is a plug-in, so Sextant is customized to the sensors a platform already carries.

Maritime first. Built to be customized for ground, aerial and legged platforms.

Explore Sextant
GPS-denied navigationJamming & spoofing detectionSelf-calibratingPlug-in sensors

02 · Autonomy

Autopilot

Missions, routes and station keeping under a safety supervisor — designed for every embodiment.

  • Missions & waypoints. Plan a mission as a sequence of waypoints and tasks, and Autopilot carries it out.
  • Line following & station keeping. Stay on the line between waypoints, or hold position when the mission calls for it.
  • Safety supervisor. Every command is checked against the vehicle’s limits before it is sent — the System 1 governor at work.
  • Built for every embodiment. On a vessel it drives Helmsman; on other platforms it is customized to their own controls.

Designed for every embodiment: vessels first, then ground, aerial and legged robots.

Explore Autopilot
Missions & waypointsLine followingStation keepingSafety supervisor

03 · Vessel control

Helmsman

One steering controller, configured for each hull instead of re-engineered.

  • One controller, configured per hull. A new vessel is a configuration file, not a new controller.
  • Commissioned from normal driving. Set up from ordinary manoeuvring — no special test programme.
  • Speed & heading control. Holds the heading and speed the mission asks for.
  • On its own or with the suite. Run it under your own guidance system, or pair it with Autopilot and Sextant.

Maritime: built for surface vessels, crewed and uncrewed.

Explore Helmsman
Per-hull configurationCommissioned from normal drivingSpeed & heading control

04 · Simulation

Basin

Virtual sea trials on real coastlines — fully repeatable.

  • Real coastlines. Trials run on real coastlines.
  • Sea, weather and traffic. Sea states, currents and other traffic, as a vessel would meet them.
  • Faults on demand. Jam the GPS, drop a sensor, degrade a signal — and see what the autonomy does.
  • Fully repeatable. Every run is recorded and reproducible: the same scenario gives the same result, every time.

Maritime: a virtual sea for surface vessels.

Explore Basin
Real coastlinesSea states & currentsSensor faultsFully repeatable

05 · Vessel models

Shipfoundry

Your hull as a simulation model, from published specifications and photos.

  • From specifications and photos. We start from what is already published about your vessel.
  • Ready for Basin and Helmsman. One model of your hull, used for virtual sea trials and for setting up steering.
  • One model per vessel. Each vessel gets its own model, built from its own data.
  • Testing before the water. With the vessel modelled, its autonomy can be trialled in Basin before the hull is launched.

Maritime: models of surface vessels.

Explore Shipfoundry
From specs & photosReady for BasinOne model per vessel

One loop

How the tools fit together

The tools connect only through published interfaces, and each one is replaceable.

  1. 01Model the vesselShipfoundry
  2. 02Prove it at virtual seaBasin
  3. 03Know where it isSextant
  4. 04Run the missionAutopilot
  5. 05Steer the boatHelmsman

Multi-embodiment

Maritime first. Built for every platform.

Our first market is the sea. But the S1 Suite is not boat software: each sensor is aplug-in and each tool sits behind published interfaces, so Sextant and Autopilot are customized to the platform in front of them — hulls, wheels, legs or rotors.

First market

Surface vessels

Crewed and uncrewed, in survey, patrol and inspection — coastal and harbour waters where GPS is unreliable or under attack.

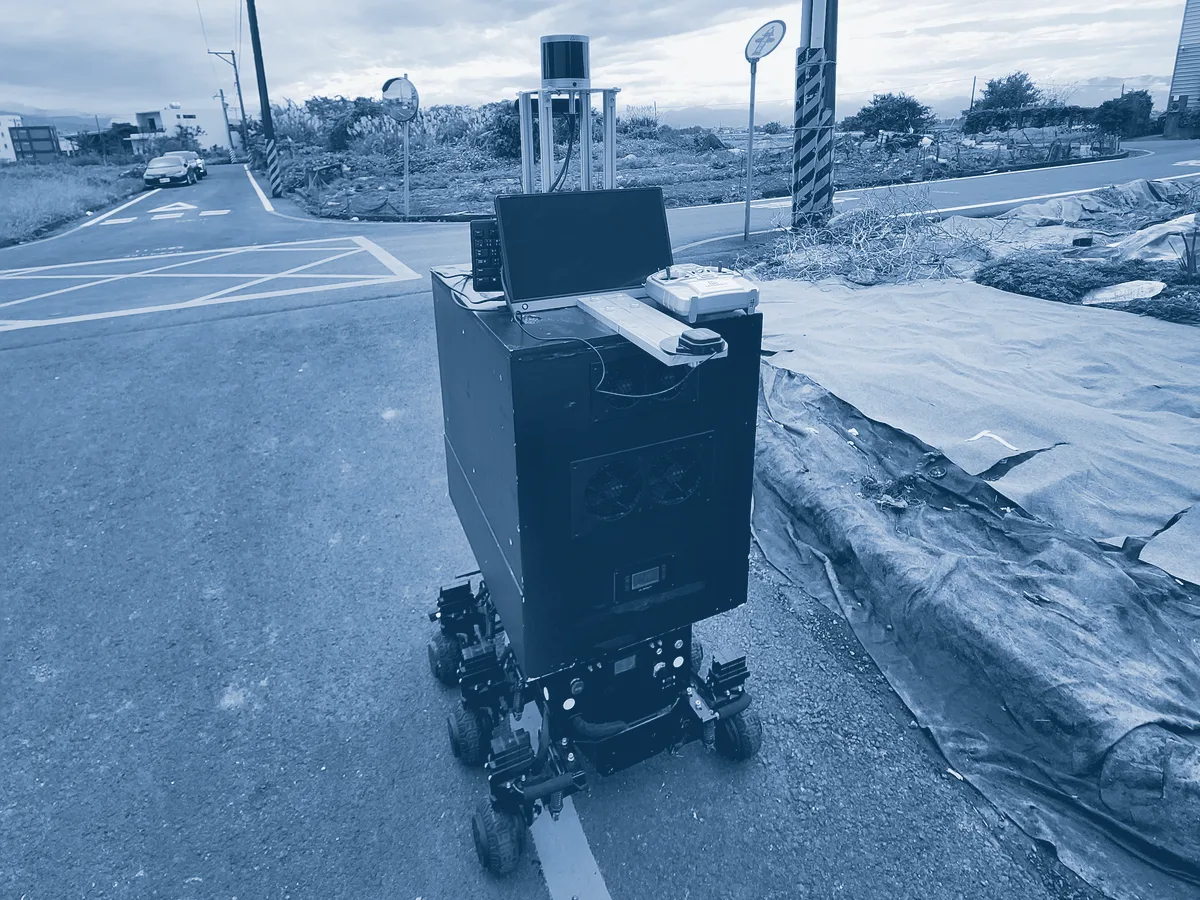
S1S2's ground rover on a test road
Customizable

Ground & legged robots

The same navigation and mission layers, customized for wheels and legs.

Customizable

Aerial

Drones that need to know where they are when GPS is jammed.

Contact

Building a robot that cannot lose its position?

We work with USV builders, survey and port operators and dual-use integrators. Built in Taiwan, for coastal waters everywhere — if that sounds like your work, let’s talk.

Emailc.argueta@s1s2.ai